DE ← Studio site

Robotics · Drones · Synthetic data

Real-time simulation software
in Unreal Engine 5 and C++

We build the environments in which control software and perception chains are tested before hardware drives or flies: software-in-the-loop over MAVLink, synthetic sensor data from the render pipeline and swarm simulation built on an entity-component-system.

Request a technical call View capabilities

Three capabilities, deliberately narrow

We are not a systems house and do not pretend to be one. We work close to the engine, where an ongoing project needs additional C++ capacity in simulation.

01 — SITL

Software-in-the-loop

Validate control software against a real-time 3D environment instead of abstract models.

  • UDP link to MAVLink v2
  • Receive in a dedicated thread (FRunnable) — the game thread stays free
  • Thread-safe hand-over via FCriticalSection
  • Attitude/thrust act through forces and torques on the airframe physics
02 — SENSORS

Synthetic sensor data

Training and test data for perception, generated directly from the render pipeline.

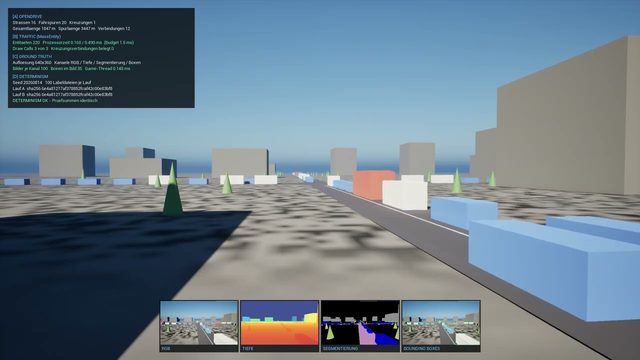
  • Depth images from scene or custom depth
  • Thermal false colour via stencil-based post-processing
  • Asynchronous render-target readback, no frame stutter
  • Raw data as a byte array for downstream AI interfaces
03 — SWARM

Swarm and mass simulation

Hundreds of units, deterministic and fast — without actor tick logic.

  • MassEntity (ECS) instead of object-oriented ticks
  • Movement behaviour in dedicated UMassProcessor stages
  • Instanced rendering (ISMC) — a large swarm with very few draw calls
  • Multithreading within chunk iteration

How we work

Plugin-first: every capability is a self-contained engine plugin, not logic scattered across the main project. That keeps integration into existing projects and hand-overs clean.

AreaImplementation
EngineUnreal Engine 5, C++20; Unreal conventions (UCLASS/USTRUCT, GC-safe UPROPERTY management)
ArchitecturePlugin-first — every feature as a separate plugin with its own build configuration
NetworkingFSocket/UDP; receive offloaded to FRunnable or TaskGraph
ConcurrencyNever block the game thread; data hand-over via mutex-protected buffers
PerformanceECS for mass entities; measured with engine profiling instead of gut feeling
RenderingScene-capture pipelines, custom depth/stencil, post-process materials, asynchronous readback
Hand-overDocumented class and threading structure; source code stays with the client

The kinship with games is no coincidence but the reason for the depth: the same mass-simulation technology powers our own real-time strategy game (studio site) and our published Unreal Engine tools. Open source code: github.com/SimulatedFlow.

Our role as a supplier

Simulated Flow UG is a micro-enterprise from Baden-Württemberg and works as a specialised engineering subcontractor (tier 2/3) — under the technical lead of the client. Typical occasions: additional engine-level C++ capacity, migration of existing simulators to UE5, building test and data-generation environments.

Maturity, stated openly: the company was founded in 2026, currently holds no ISO/EN certifications (9001, EN 9100, AQAP) and does not act as a general contractor. A working demonstrator covering all three fields exists — PX4 unmodified in software-in-the-loop, with synthetic sensors and 500 swarm entities in the same scene. It runs right here, uncut; code review and a technical deep dive on request. Where certification, security clearance or approvals are a prerequisite, we say so beforehand — not afterwards.

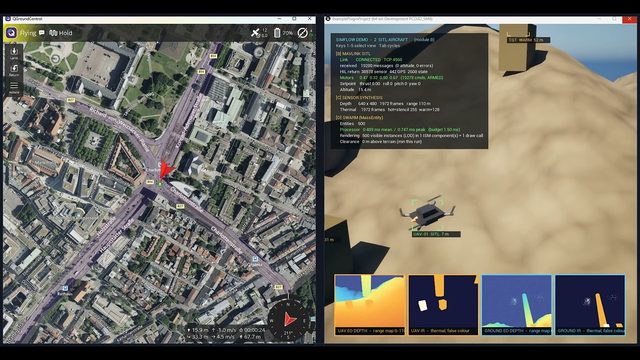
Demonstrator — 85 s, uncut

PX4 unmodified in software-in-the-loop against QGroundControl · about 29,500 MAVLink messages with 0 attitude and 0 transmission errors · depth and thermal images at 640 × 480 each (2,898 images per channel, range 110 m) · 500 MassEntity agents at 0.43 ms mean CPU time (budget 1.50 ms) in a single draw call. All figures come from this run.

More demos on YouTube
The videos open on YouTube. Nothing is loaded from YouTube or Google until you click; the preview images are hosted on our own server.

Legal form
UG (haftungsbeschränkt), German limited liability company
Seat
Ottersweier, Baden-Württemberg
Founded
2026
Commercial register
Amtsgericht Mannheim, HRB 758925
VAT ID
DE463825106
Employees
1 (managing director) — micro-enterprise by EU definition

For procurement and contracting authorities

We are registered on the relevant procurement platforms and listed for the matching CPV categories — including restricted tenders and negotiated procedures. The capability statement is available for download right here; you do not need to request it.

Registrations & identifiers

  • ▪ NCAGE CNNQ0 — assigned on 17 Aug 2026 by the German national codification authority (Bundeswehr Logistics Command)
  • ▪ EU-PIC 862644669
  • ▪ Federal e-procurement platform (e-Vergabe des Bundes)
  • ▪ Deutsches Vergabeportal (DTVP)
  • ▪ Vergabemarktplatz Baden-Württemberg
  • ▪ TED — Tenders Electronic Daily (EU)

Self-declarations of suitability, information on exclusion grounds under sections 123/124 GWB, and declarations on MiLoG and LTMG are provided promptly on request.

Capability statement

One A4 sheet with capabilities, company data, identifiers and the measured figures of the demonstrator — the same document we attach to tenders and supplier enquiries. No form, no sign-up.

Capability statement (PDF, A4, German)

Our maturity is stated openly in it: founded 2026, no ISO/EN certifications, no completed public contracts as references.

CPV categories

We are registered as a supplier under these codes:

  • 72200000
  • 72212132
  • 72260000
  • 48000000
  • 34711200
  • 34150000
  • 73000000
  • 73420000

Export control & compliance

We are set up to complete export-control questionnaires (ECD, including ITAR/EAR applicability), to acknowledge supplier codes of conduct, and to provide self-declarations through the platforms you use.

Contact

For tenders, supplier self-declarations, an NDA or a technical deep dive, a short message is enough. We answer with substance, not brochures.

Simulated Flow UG (haftungsbeschränkt)

Silvan Teufel, managing director
Zeller Straße 37 A · 77833 Ottersweier · Germany
simulatedflow@gmail.com
+49 160 5170640

What helps

  • Which capability is it about (SITL, sensors, swarm)?
  • Engine version and existing codebase
  • Timeframe and type of engagement
  • Required approvals or certifications

Open an enquiry with these four points